Robotics
Two seasons in the FIRST Robotics Competition, with three district event wins between them.
2025 REEFSCAPE
Team 10332, Carroll Charger Robotics
Carroll High School, Fort Wayne, IN
Rookie season. I was the team's only programming and electrical student.
- Handled all programming and electrical work for the team's kitbot
- Learned the technical details of FRC robots, including autonomous path planning with PathPlanner
| Event | Qual rank | Playoffs | Awards |
|---|---|---|---|
| FIN District Mishawaka | 12 of 36 (6-6) | Event winner First event in team history. Alliance 1 (second pick), 5-0 in playoffs | District Event Winner |
| FIN District Kokomo | 15 of 40 (6-6) | Alliance 4 (second pick), 1-2 | |
| FIRST Indiana State Championship | 37 of 38 (2-10) | Did not participate | Rising All-Star Award |
- Season record: 20-24
- Finished 29th of 76 in Indiana district points and qualified for the State Championship as a rookie team
2026 REBUILT
Team 1501, Team THRUST
4-H, Huntington, IN. Founded in 2005
Robot: R.A.P.T.O.R., a turret bot.
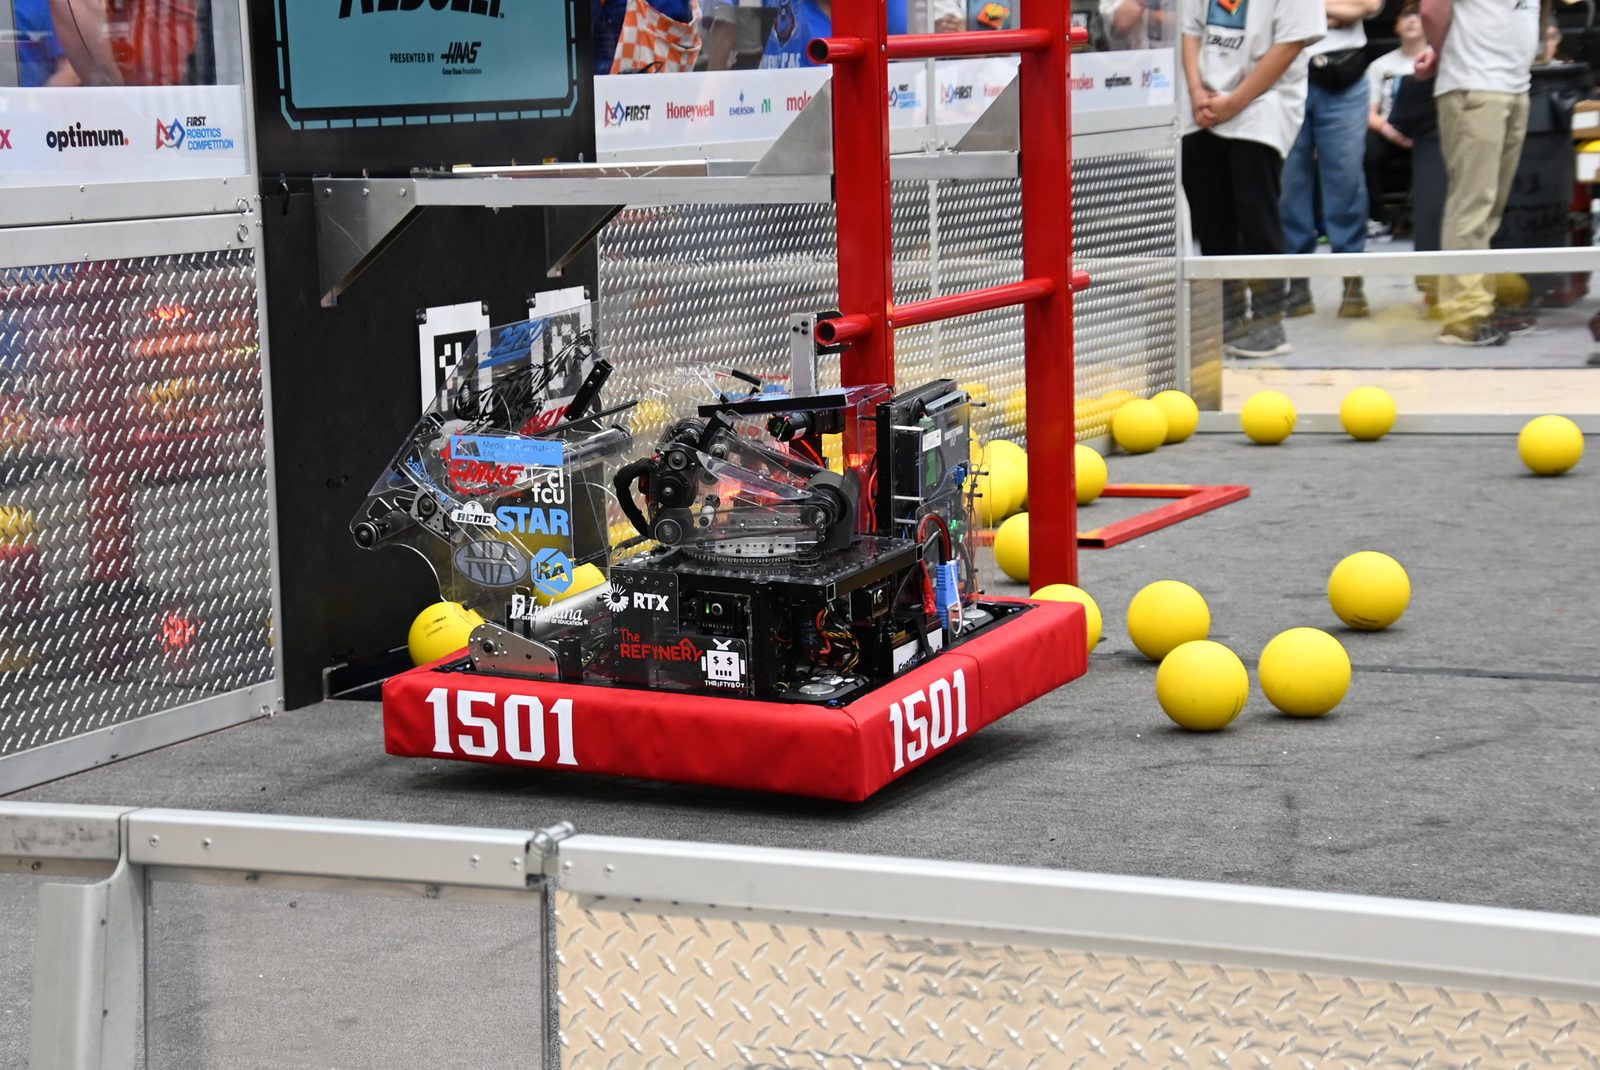
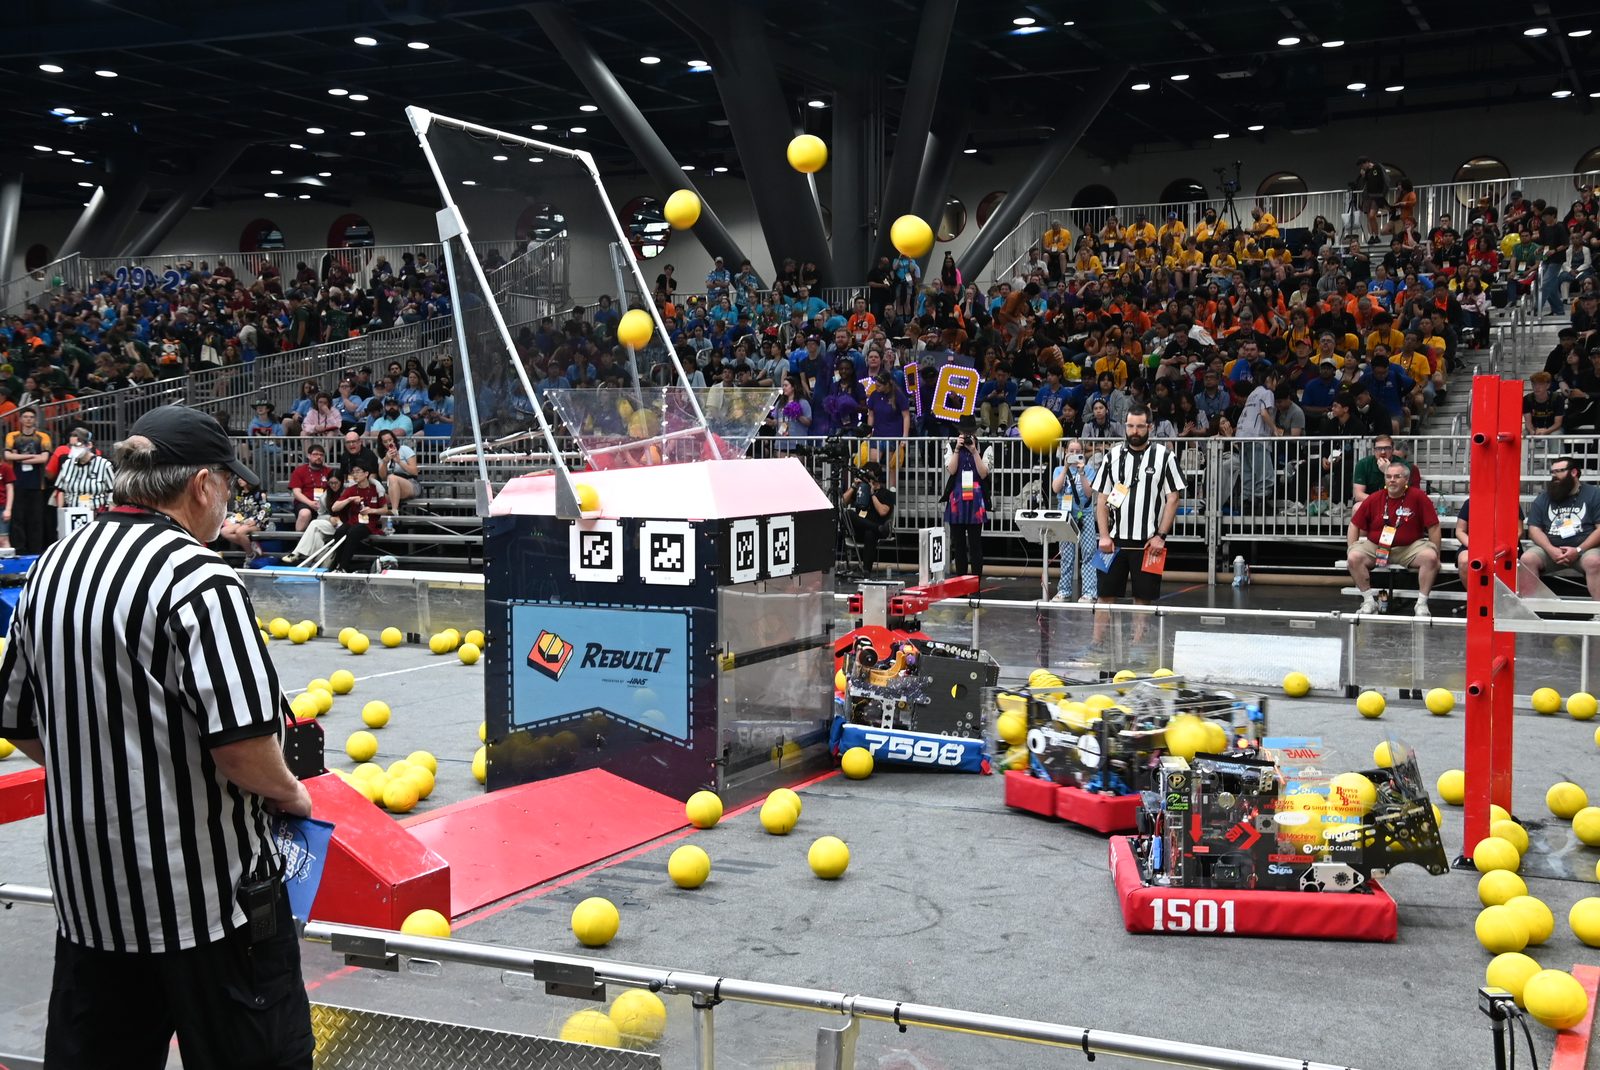
- Learned vision systems and how to aim a turret
- Most frequent committer on the 2026 robot code (82 of 181 commits)
- Wrote the firmware for two custom circuit boards
| Event | Qual rank | Playoffs | Awards |
|---|---|---|---|
| FIN District Mishawaka | 1 of 39 (12-0) | Event winner Alliance 1 captain, 5-1 | District Event WinnerImagery Award |
| FIN District Lafayette | 2 of 35 (10-2) | Event winner Alliance 1 first pick, 5-0 | District Event WinnerInnovation in Control Award |
| FIRST Indiana State Championship | 6 of 38 (9-3) | Alliance 5 captain, 1-2 | Quality Award |
| FIRST Championship, Archimedes Division | 62 of 75 (3-7) | Did not participate |
- Season record: 45-15
- Finished 6th of 77 in Indiana district points and qualified for the FIRST Championship
- Statbotics EPA rank: 442 of 3,724 teams worldwide (top 12%)
Robot software
Turret aiming and vision
Team 1501's 2026 robot aims its turret from the robot's position on the field, so a shot does not depend on seeing the target directly.
- The robot's hardware map lists four Limelight 4 cameras, and vision pose estimates are fused into swerve odometry
- Aiming accounts for robot motion: it uses the turret pivot's field velocity, from both driving and rotation, and the fuel's flight time to predict where to aim
- A shot calibration table maps distance to flywheel speed, hood angle and flight time, with separate profiles for scoring and for feeding to the ground
- Live tuning and a shot trajectory display run through NetworkTables
Custom boards
Firmware for two boards
I wrote the firmware for the driver station button board and the voltage stabilizer.